Problem
Cleaning solar panels without water couples surface contact, traction, cleaning reach and motion control.
Architecture
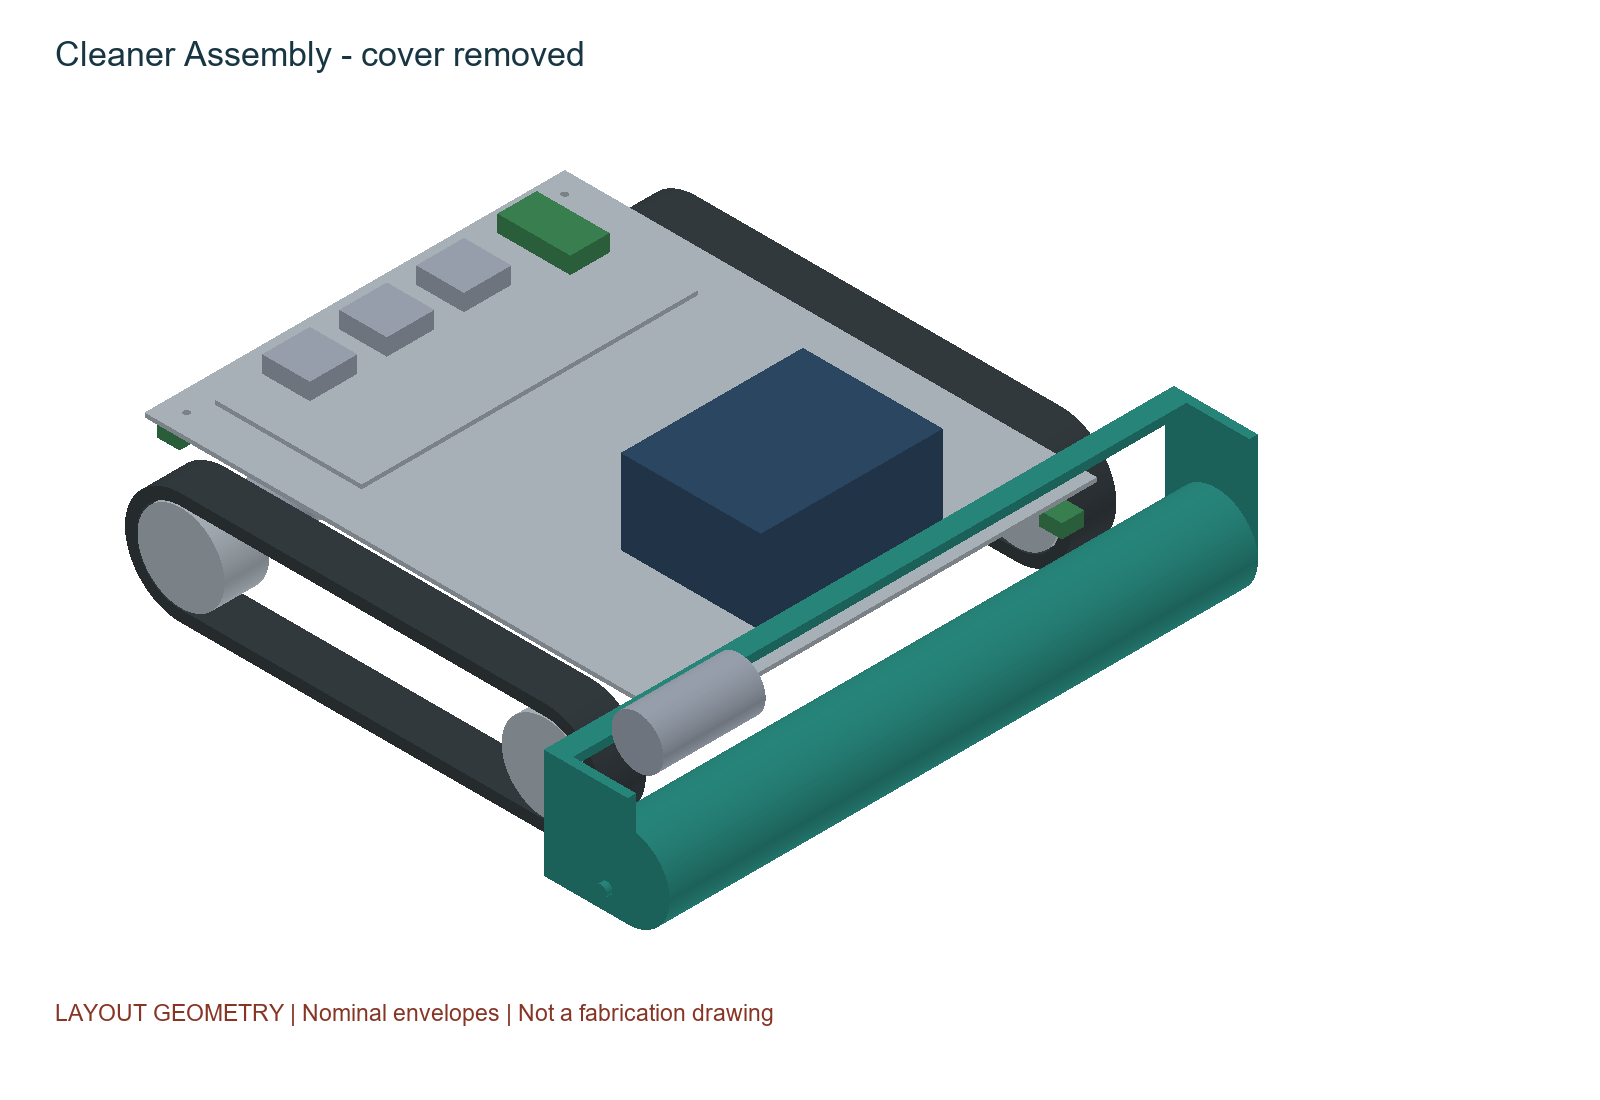
The mechanical design separates the chassis, track pods and cleaning roller, with docking and loading interfaces. Supervisory control manages operating states and fault handling, while the analytical work examines contact forces, drive torque, energy and coverage geometry.
Design decisions
- 01Considered brush loading and traction together because cleaning contact changes both resistance and available track loading.
- 02Examined the trade-off between keeping the platform inside a panel boundary and allowing the brush to reach its edges.
- 03Kept mechanical modules and control interfaces explicit to support inspection, maintenance and further development.
Verification
The hardware has been built and functionally tested. The paper separately presents reproducible analytical calculations and archived software checks: 40,184 supervisor assertions and 870 coverage-planner assertions. Numerical force, torque, energy and coverage figures are modelled results.